ETH Zurich Uses Printed Hydrogels to Drive Muscle-Powered Robots
ETH Zurich researchers combined volumetrically printed hydrogel scaffolds with living muscle tissue to create biohybrid actuators, reporting up to elevenfold greater motion in selected comparisons.
Living muscle meets a printed scaffold
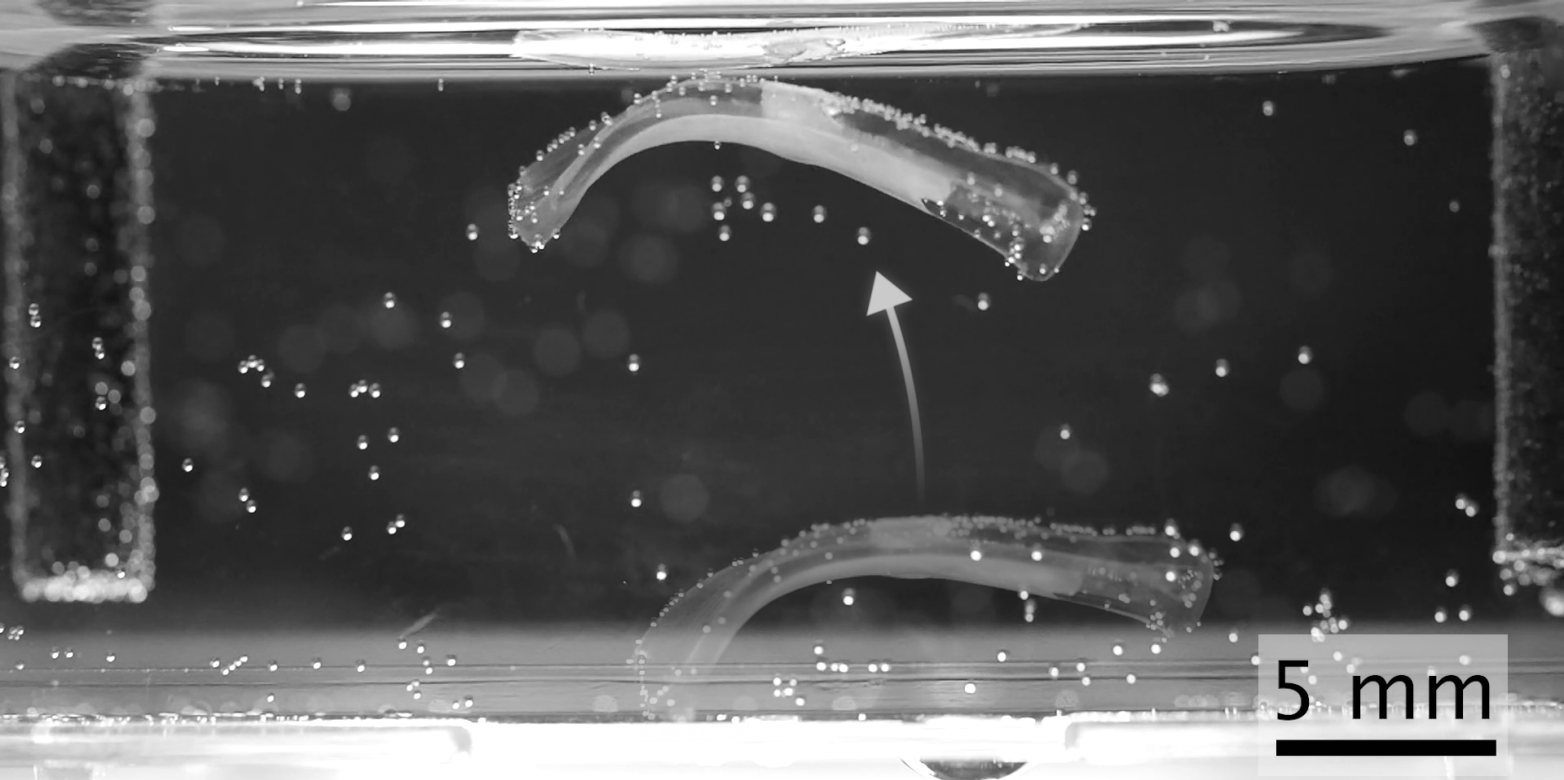
ETH Zurich researchers reported biohybrid actuators made from cultured mouse skeletal muscle tissue and flexible 3D-printed hydrogel scaffolds. The roughly 1.5 cm devices move through muscle contraction rather than a conventional motor.
Xolography and force transfer
The scaffolds were produced with light-based volumetric xolography, taking about a minute per structure. Fine grooves help anchor and align muscle fibers. The team co-optimized muscle and scaffold geometry to translate contraction into useful movement more efficiently.
Promising but still experimental
In selected comparisons, the actuators achieved up to eleven times the range of motion at similar muscle mass. Demonstrations included swimming, crawling, grasping and jumping. Long-term operation still requires nutrients, oxygen supply and biological control. This is a research platform, not a ready-to-deploy industrial robot.